


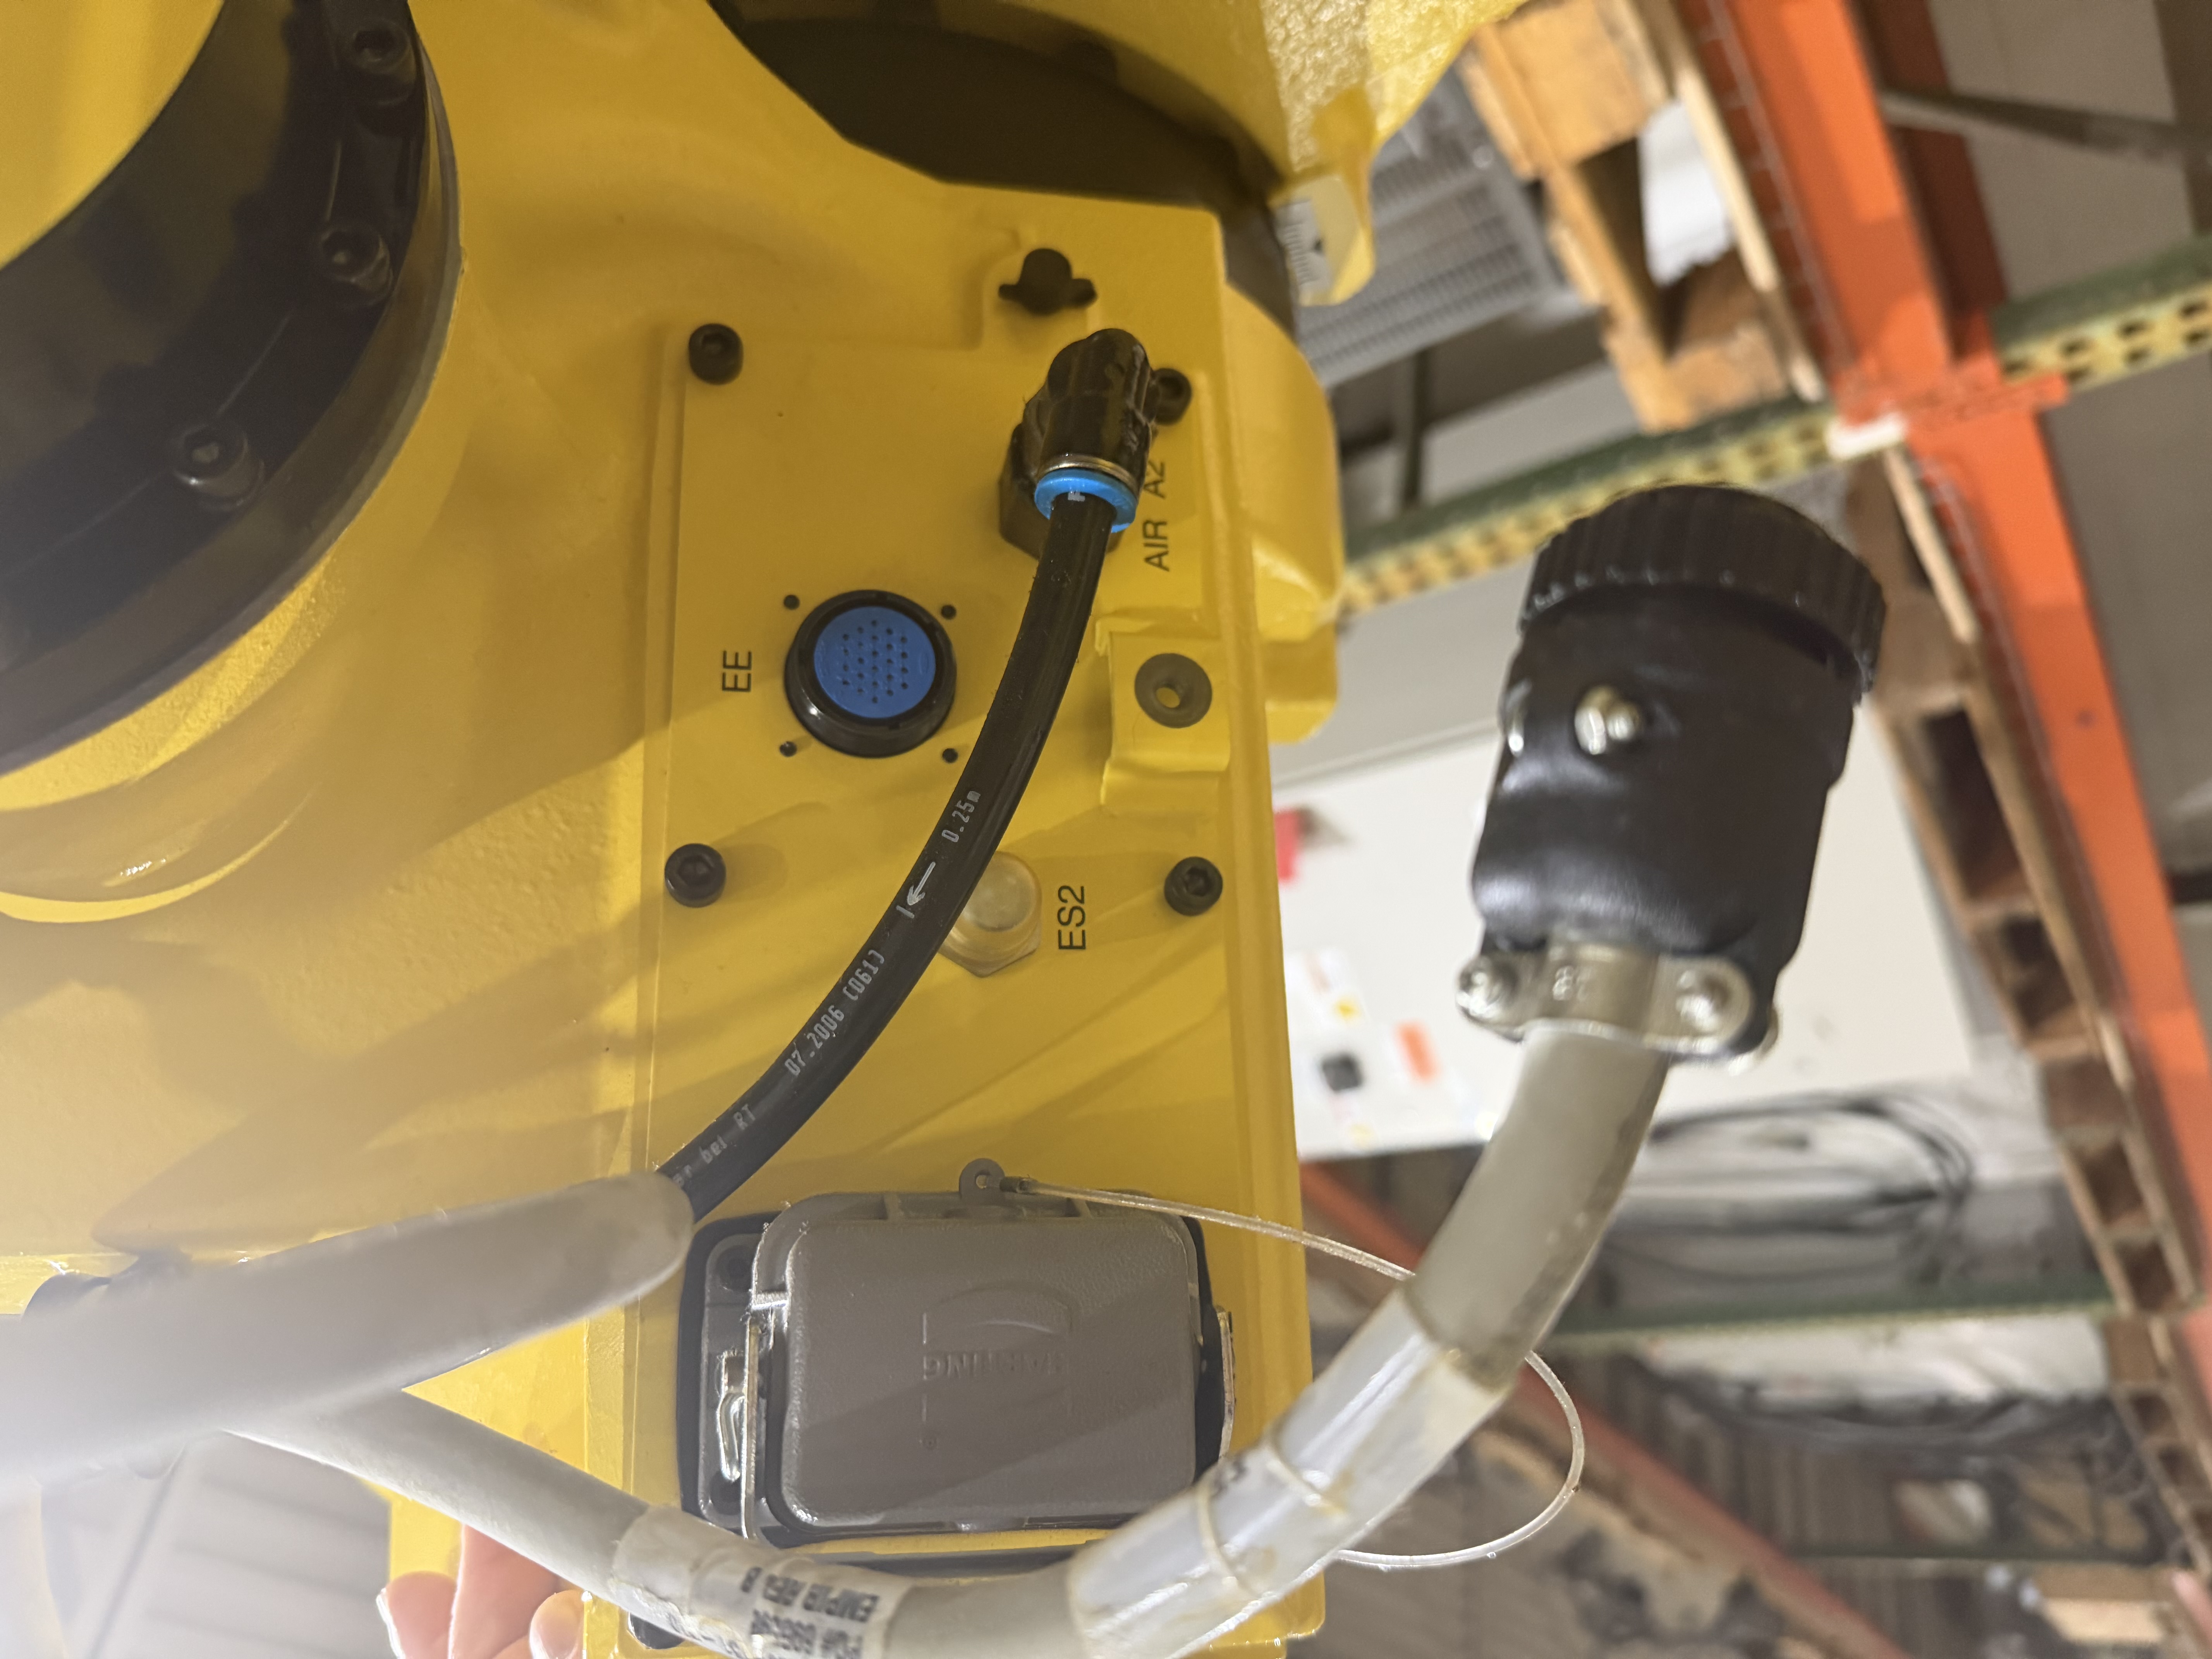
On a FANUC robot, ES stands for Ethernet Switch or End-effector Ethernet (Secondary), depending on whether you are referencing the software/hardware option or the physical connector labeling.
In official FANUC documentation for the internal cable routing option, it is most commonly designated as part of the EE-Ethernet layout, where ES differentiates the Ethernet/Data lines from the standard EE (End-Effector) 24V discrete I/O lines.
Meaning Breakdown
- E = Ethernet
- S = Switch / Secondary / Service (Specifically denoting the network data path running to the tool, separating it from the primary EE analog/digital control signals).
- ES1 = Ethernet Source / Station 1 (The network input at the controller cabinet).
- ES2 = Ethernet Sub-station / Station 2 (The network output at the tool flange).